Projects
Liquid Rocket Engine Throttle Controller
A Python and Qt desktop application for the SwanSEDS Kilgharrah engine programme, bringing throttle sequences, controller communication and hardware status into one interface.
Key Details
- Application: Desktop interface for an Arduino-based throttle controller
- Programme: SwanSEDS Rocketry — Kilgharrah
- Stack: Python, PySide6, Qt Designer and PyQtGraph
- Communication: TCP commands over Ethernet and UDP telemetry
- Date: July 2026
- Status: In development
From throttle profile to controller
The application supports the development of throttle control for Kilgharrah. A graphical desktop interface brings together the preparation of test sequences, communication with the controller and feedback from the hardware.
Qt Designer defines the interface, while Python handles connection management, sequence conversion, plotting and status updates.
Sequence preparation and visualisation
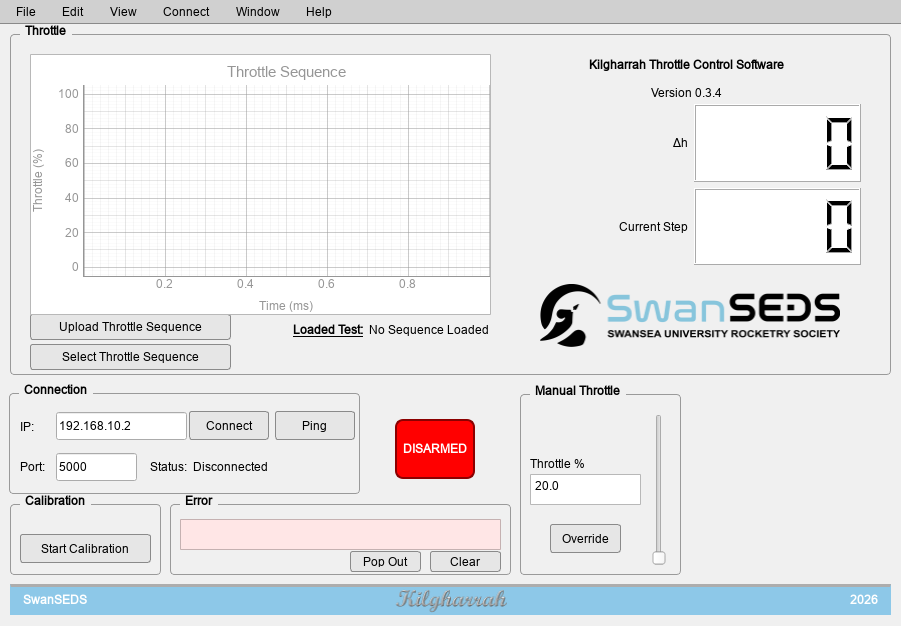
CSV throttle profiles can be converted into command sequences for the Arduino controller. The interface provides sequence selection, a graph of the loaded profile and an upload control, keeping the planned throttle behaviour visible alongside the controller readouts.
Connection and hardware feedback
Configurable IP address and port settings, connection controls and a ping function support Ethernet communication with the Arduino. The software includes UDP telemetry handling, an armed-state indicator and an error log with a separate pop-out window.
Calibration and manual control
A calibration control and manual throttle slider provide tools for controller development. The manual control logic constrains requested throttle values to the configured 20–100% range.
Development status
The repository describes this software as in development and not yet flight-ready, test-stand-ready or safety-certified. The page documents its interface and implemented software features; hardware validation remains part of the development programme.